
时间:2023年4月4日 16:00
地点:机械与动力工程学院 F310会议室
报告人:Dr. Yu Haoyong (National University of Singapore)
邀请人:谷国迎 教授( 机器人研究所 )
Biography
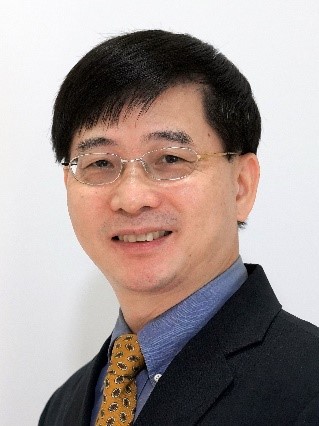 Dr. Yu Haoyong is an Associate Professor of the Department of Biomedical Engineering at the National University of Singapore. He received his Bachelor’s Degree and Master’s Degree from Shanghai Jiao Tong University and his PhD degree from Massachusetts institute of Technology (MIT). His current research interests include biomedical robotics and devices, rehabilitation engineering and assistive technology, service robots, human robot interaction, intelligent control and machine learning.
Abstract
Tactile sensing is essential for human when grasping and manipulating objects in daily life. Similarly, service robots rely on tactile sensors to estimate the grasping force magnitude, contact location and force direction when grasping objects in order to improve objects manipulation safety. However, the current robotic tactile sensing solution have serious limitations regarding to simplicity, sensitivity, robustness, and bulkiness.
Integration of tactile sensors and robotic hands is still not common in current service robots. We develop a biomimetic tactile sensing hardware, GTac, which can estimate task-essential contact information, i.e. contact force and force direction, and easily integrated for robotic hands. GTac adopts multilayer structure consisting of separate layers for intrinsic tri-axis force sensing and dense extrinsic normal force sensing to mimic the functions of SA-II and FA-I tactile afferent in human skin.
Based on the novel tactile sensor, we develop an anthropomorphic robotic hand to equip GTac at fingertips and palm. Since anthropomorphic hand has a natural adaptability to human daily environment, GTac at fingertips and palm such contact-rich positions can perceive essential contact information for grasping, in-hand manipulation, etc. In Total, the robotic hand can perceive 285 tactile signals.
In this talk, we will introduce the design and fabrication of the sensor and demonstrate the sensing and grasping capability of the robotic hand and gripper.

地址:上海市闵行区东川路800号机械大楼A楼209室
联系电话:021-34205880
版权所有 © 2025 机械系统与振动全国重点实验室
沪交ICP备2010739